Key figures
By the numbers
~9 days
Early warning from thermography before the bearing reaches 85 °C
6 / 6
Correct readings in demo 2 (display, thermal, ultrasound, 2 valves and gauge)
3
Work orders raised by the robot on its own, with evidence
0
Collisions: the robot detected an unmapped pallet and re-planned
Demo 1 · Video
Basic patrol, start to finish
1 min 58 s · 3 points, vision reading of gauges and panel, MQTT telemetry to SCADA.
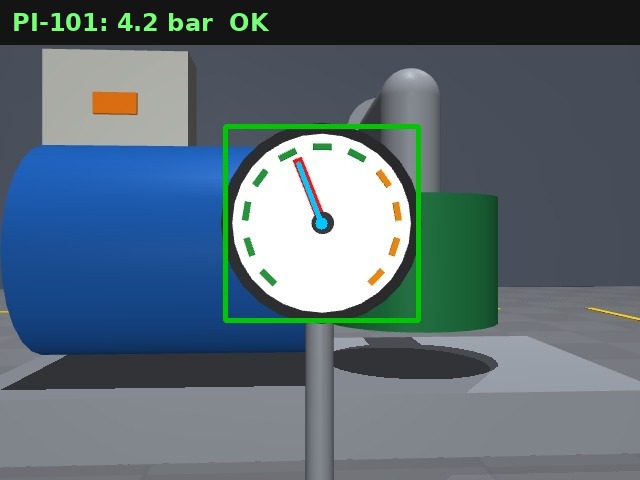
PI-101 · Pump P-101 · 4.2 bar · OK
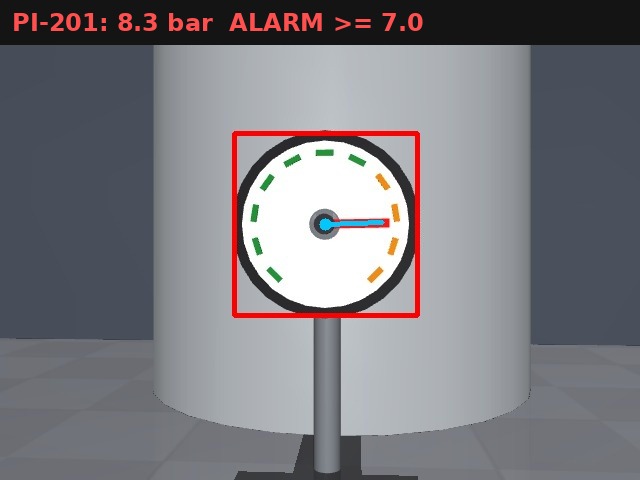
PI-201 · Tank TK-201 · 8.3 bar · ALARM
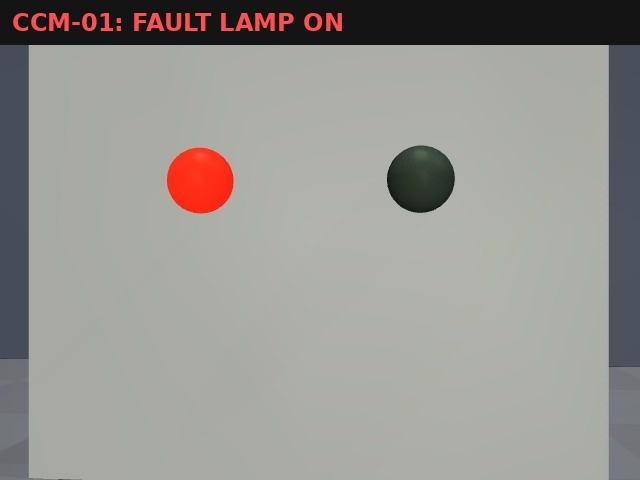
CCM-01 · Panel · Fault · ALARM
Demo 2 · Video
Incipient pump failureNEW
2 min 30 s · Map and obstacle avoidance, digital display, thermography with trends, ultrasonic leak, valves, cross-diagnosis, work orders and automatic PDF report.
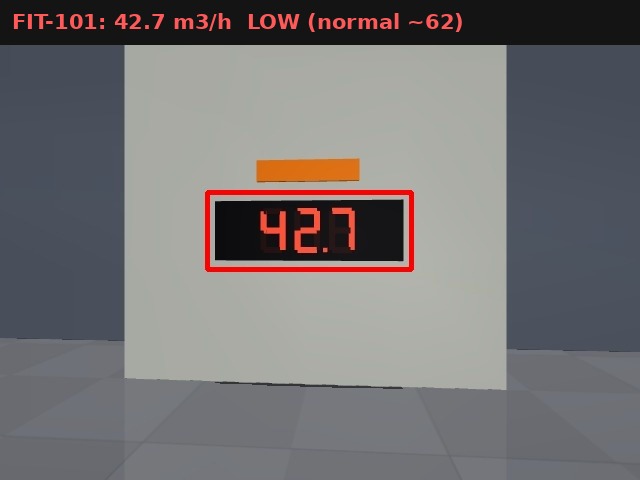
FIT-101 · Flow · 42.7 m³/h · LOW
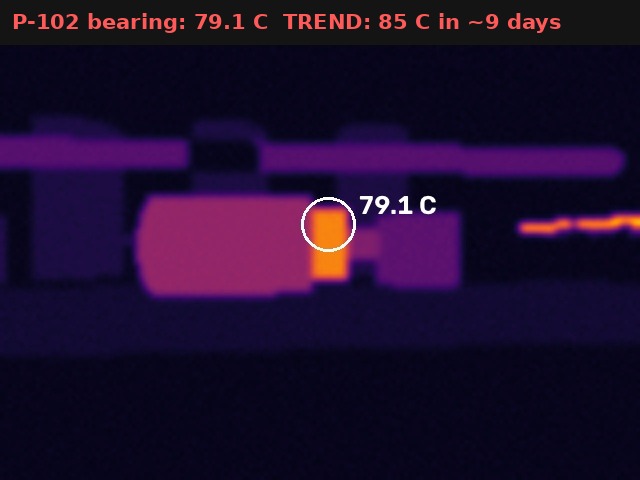
TT-102 · P-102 bearing · 79.1 °C · 85 °C in ~9 days
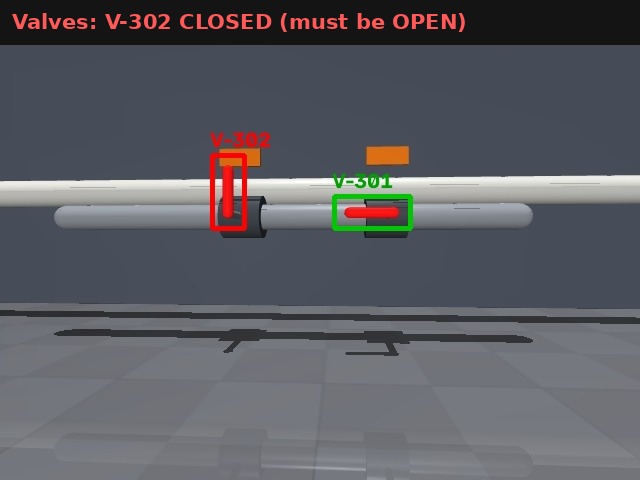
V-302 · Valve · CLOSED · must be open
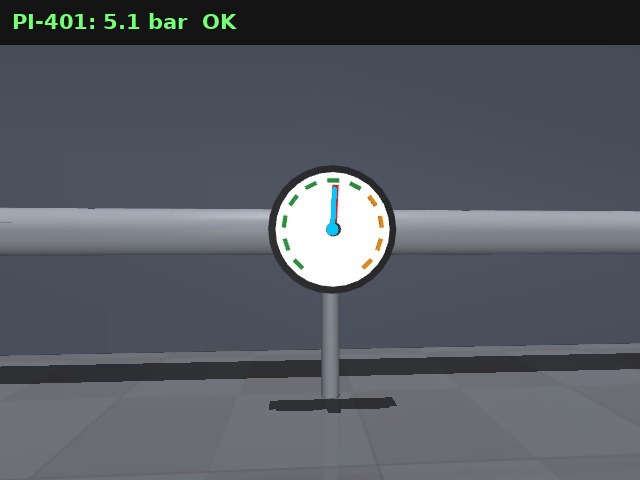
PI-401 · North header · 5.1 bar · OK
Demo 1
Basic patrol: read and report
The first demo: 3 points, vision reading and MQTT telemetry.
Locomotion and navigation
Our own 500 Hz trot controller and waypoint navigation using the robot's position and heading.
Vision reading
Reads analog gauges with a max error of ±0.2 on a 0–10 scale and detects fault lamps on panels.
Telemetry to SCADA
Status, readings and alarms as JSON over MQTT: 256 of 256 messages received.
The same SDK as the real robot
Only official unitree_sdk2 channels (rt/lowcmd, rt/lowstate, rt/sportmodestate).
Demo 2 · What it does
From symptom to diagnosis, unprompted
The robot does not just read: it compares, correlates and acts.
1Map-based navigation
Plans its route with A* on the plant map. Its depth camera detects a pallet that is not on the map and it takes the alternate route through the central aisle.
2Thermography with trends
Measures 79 °C on the P-102 motor bearing. Not at the limit yet, but compared with previous patrols it rises 4.4 °C per week: 85 °C in ~9 days. It raises a predictive work order.
3Listens for leaks
Its ultrasonic microphone (38–42 kHz) monitors the whole route. It detects and locates a steam leak at flange FL-12 and raises a work order.
4Correlates findings
Reads low flow on display FIT-101 and finds valve V-302 closed. It concludes the valve explains the low flow and reports it to Operations.
Demo 2 results
What the robot found
Readings from the run in the video, exactly as they reached SCADA.
FIT-101 · Discharge flow
Display: 42.7 m³/h (normal ~62). Low flow.
⚠ FINDINGSee evidence
TT-102 · P-102 motor bearing
79.1 °C and rising: 85 °C in ~9 days. Predictive WO.
⚠ FINDINGSee thermography
US-12 · Steam line
Ultrasound 53.4 dB vs 31 dB baseline next to flange FL-12. Leak WO.
⚠ FINDINGSee acoustic map
V-302 · Discharge valve
CLOSED; must be open. Explains the low flow.
⚠ FINDINGSee evidence
V-301 · Discharge valve
Open, as expected.
✔ OKSee evidence
PI-401 · North header
5.1 bar, within range.
✔ OKSee evidence
Work order published by the robot over MQTT (topic bonum/planta_demo/robot/go2-01/orden_trabajo):
(Field names in Spanish, as used by our SCADA/CMMS integrations in Mexico.) At the end, the robot generates the patrol PDF report on its own.
{"folio": "OT-20260924-01", "equipo": "Bomba P-102 (motor)", "falla": "Temperatura de rodamiento en ascenso: 79.1 °C (+4.4 °C/semana)", "prioridad": "Alta", "dias_a_limite": 9.4}(Field names in Spanish, as used by our SCADA/CMMS integrations in Mexico.) At the end, the robot generates the patrol PDF report on its own.
Technology
What is behind the demos
Open tools and industrial standards; nothing closed or locked to one vendor.
Is it an animation? → No. It is a physics simulation (MuJoCo) with the official robot model: gravity, contacts, masses and torque limits. The robot walks because our controller keeps it balanced. If the controller fails, the robot falls.
Are the sensors real? → The color and depth cameras are rendered from the scene. The thermal camera and ultrasonic microphone are simulated models: per-equipment temperature and a sound level that decays with distance to the leak. On the real robot they are replaced by physical sensors.
What about the history? → The trend uses 6 previous weekly demo patrols. With the robot in a plant, its own patrols build the history. The trend logic is the same.
Does it integrate with my SCADA and CMMS? → Telemetry and work orders go out as JSON over MQTT. For OPC UA, Modbus or your CMMS API we add a gateway: that is BONUM's core automation work. PLC/SCADA is our specialty.
Roadmap
Plan and phases
Phase 1
BONUMSimulation demos (today)
- Demo 1: basic patrol
- Demo 2: incipient pump failure
- PDF report and work orders
Phase 2
BONUMPhysical robot
- Same program on the real robot
- Physical thermal camera and ultrasonic microphone
- Tests at our facilities
Phase 3
BONUM + customerPlant pilot
- Survey of points to inspect
- Integration with the customer's SCADA and CMMS
- Assisted operation and results report
Architecture
Patrol data flow
From the robot's sensors to the work order.
Let's build inspection solutions together
BONUM is an industrial automation and AI integrator in Querétaro, Mexico. We would be glad to hear your feedback on these demos.
WhatsApp[email protected]